2. SDK Client Dynamic Library Usage
Using the SDK library requires a host computer, where the SDK establishes communication with the robot controller via TCP connection. Ubuntu is recommended; Windows is currently unsupported. The required file directory for executing the SDK is shown below.
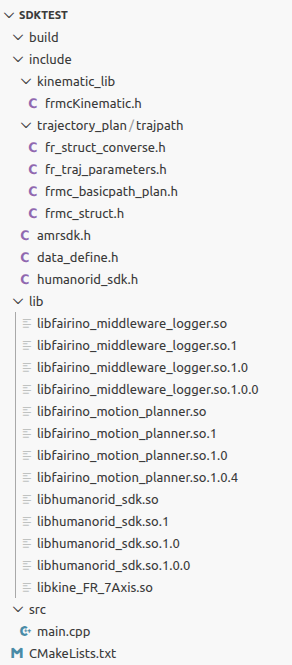
Figure 2-1 SDK Library Directory
Note
Note: 1. Ensure that the dynamic libraries libfairino_middleware_logger, libfairino_motion_planner, and libkine_FR_7Axis are placed in the same directory as the libhumanorid_sdk dynamic library.