3. Product Introduction
3.1. Product Dimensions
The overall dimensions of both the left and right arms are 901mm×128mm×128mm, as shown in Figures 3-1 and 3-2.
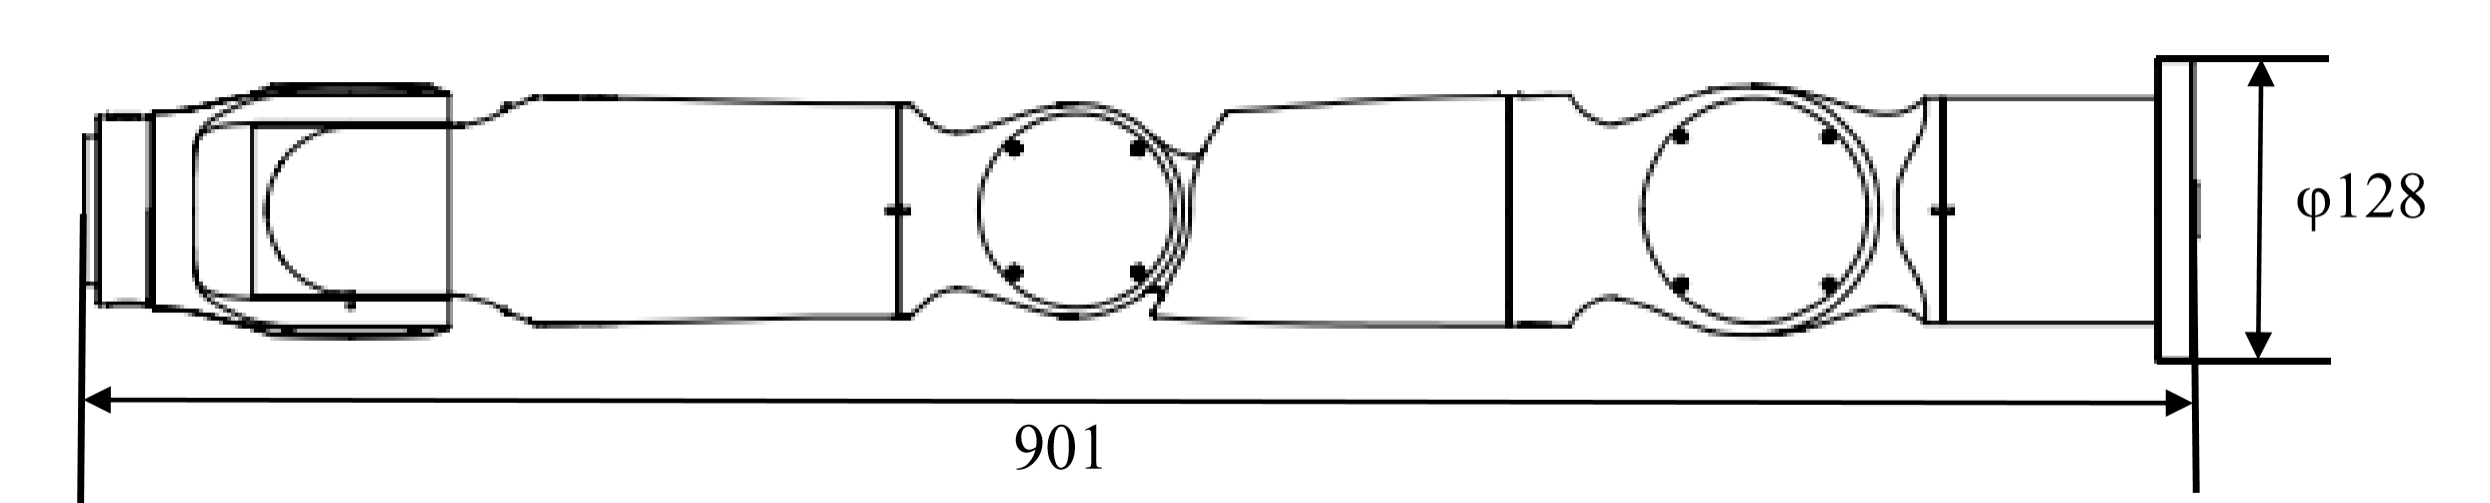
Figure 3-1 Left Arm Outline Dimensions
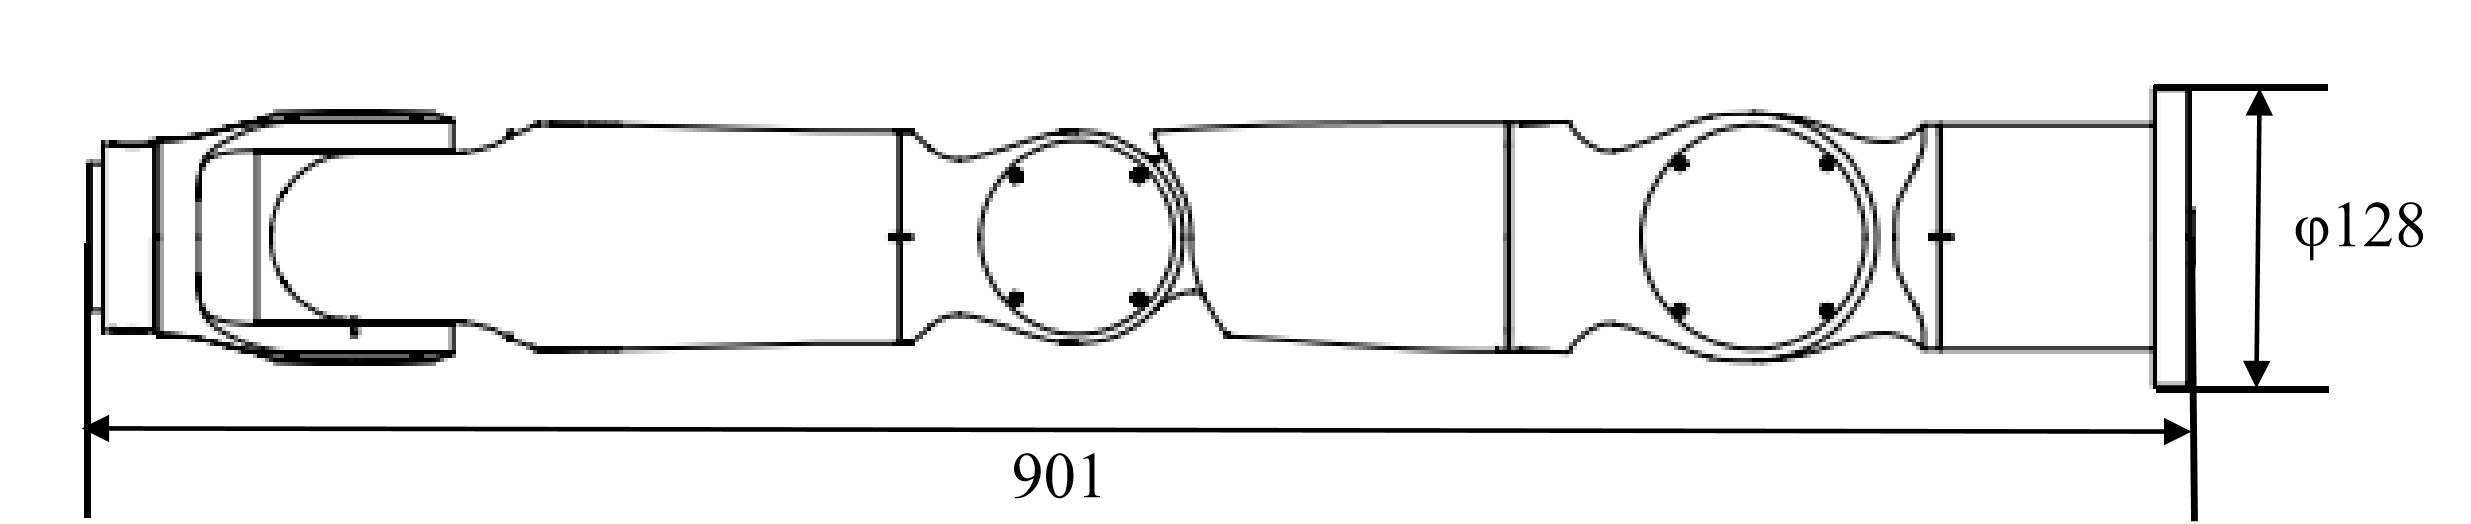
Figure 3-2 Right Arm Outline Dimensions
3.2. Nameplate Information
The nameplate information for the single-arm configuration and the packaging box is shown in Figures 3-3 and 3-4.
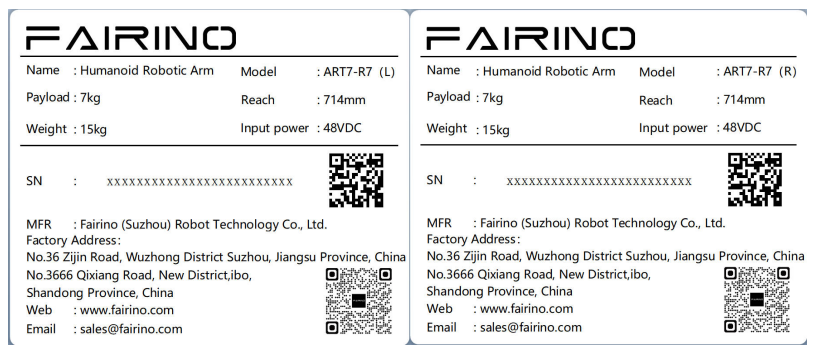
Figure 3-3 Configuration 1 Single-Arm Nameplate Information
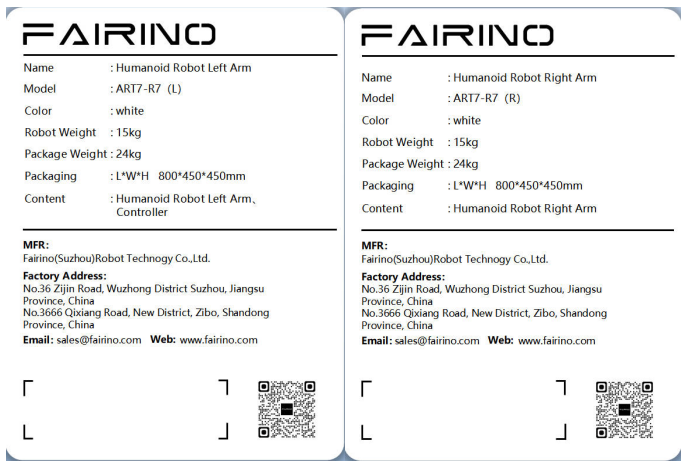
Figure 3-4 Configuration 1 Packing box nameplate information
The nameplate information on the Configuration 2 single-arm + controller and packaging box is shown in Figure 3-5 and 3-6.
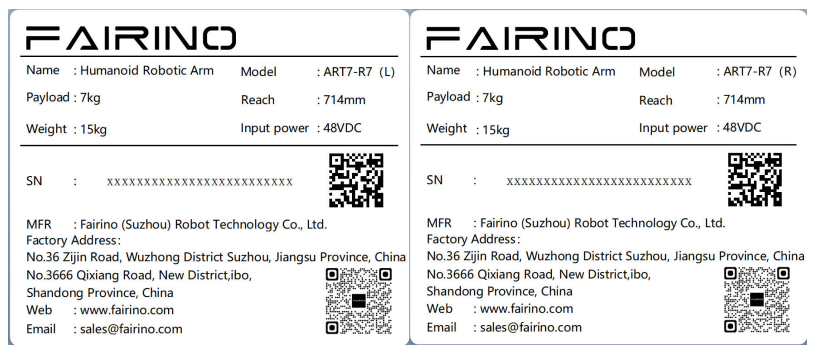
Figure 3-5 Configuration 2 Single-Arm Nameplate Information
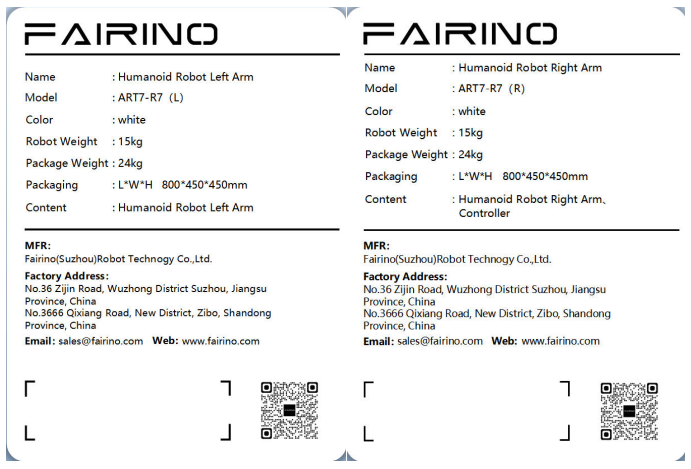
Figure 3-6 Configuration 2 Packing Box Nameplate Information
The nameplate information for the three-arm configuration and the packaging box is shown in Figures 3-7, 3-8, and 3-9.
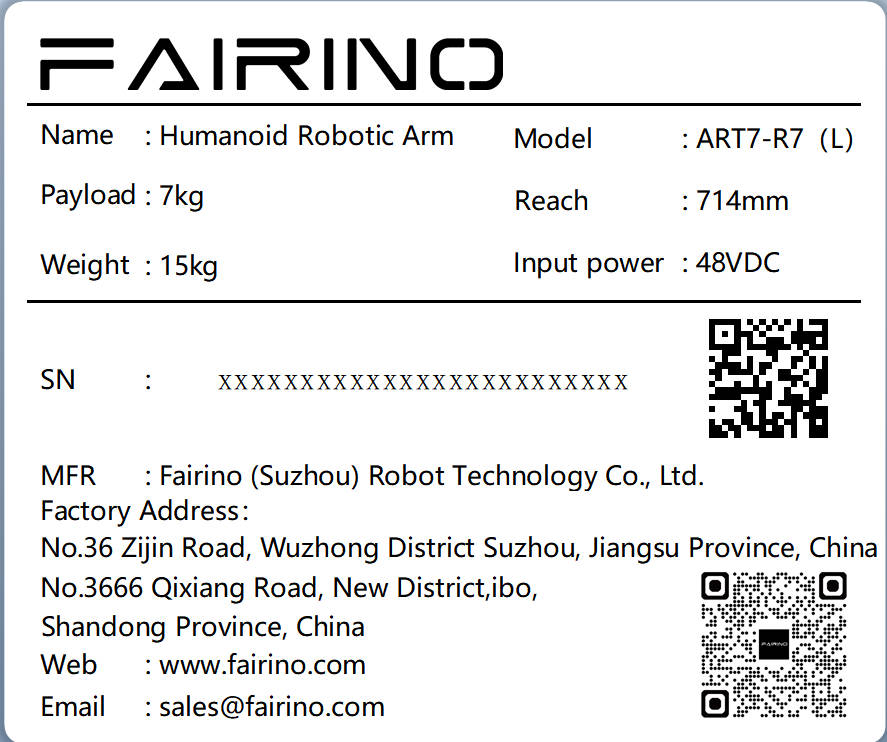
Figure 3-7 Configuration 3 Left Arm Nameplate Information
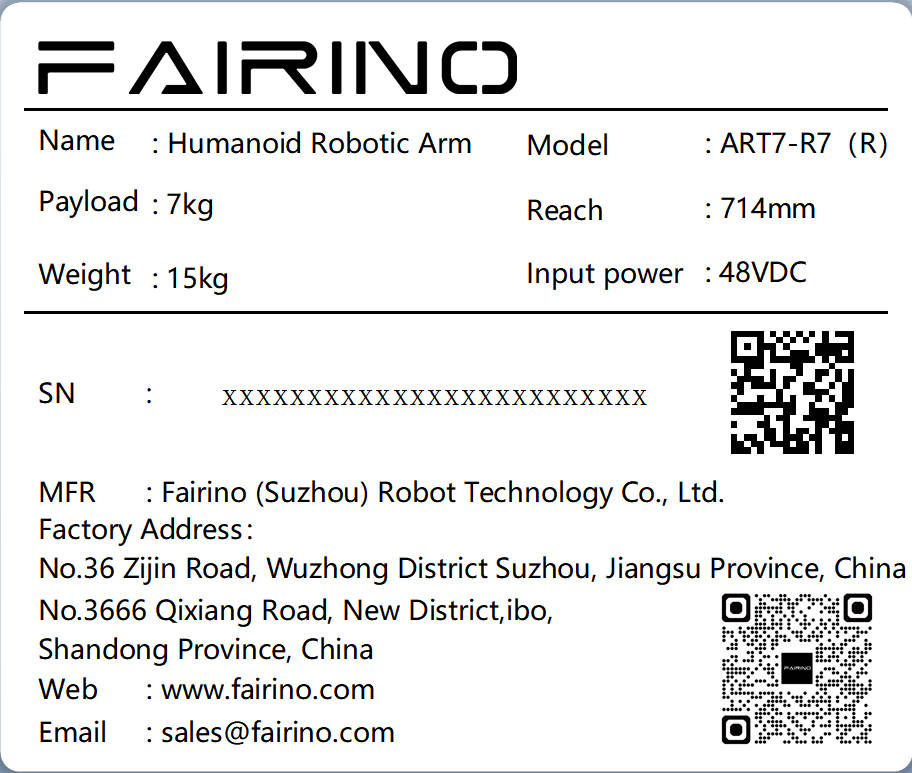
Figure 3-8 Configuration 3 Right Arm Nameplate Information
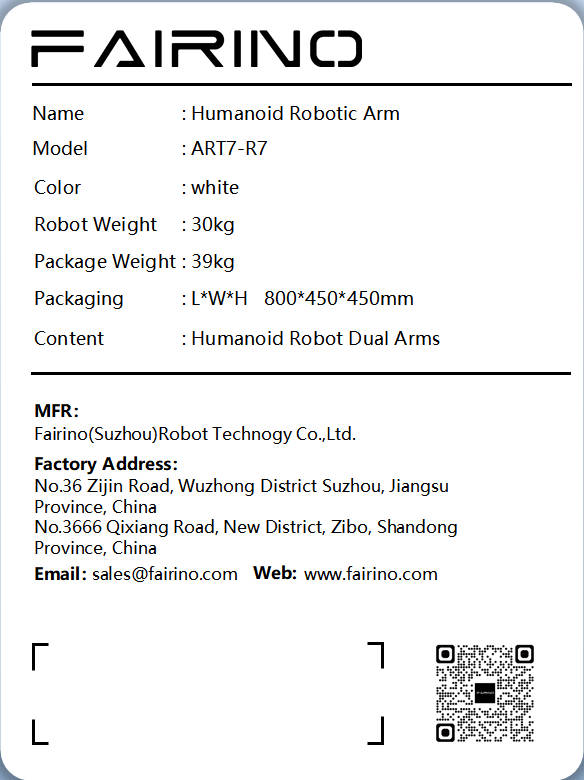
Figure 3-9 Configuration 3 Packaging Box Nameplate Information
The nameplate information for the four dual arms, controllers, branch units, and packaging boxes is shown in Figures 3-10, 3-11, and 3-12.
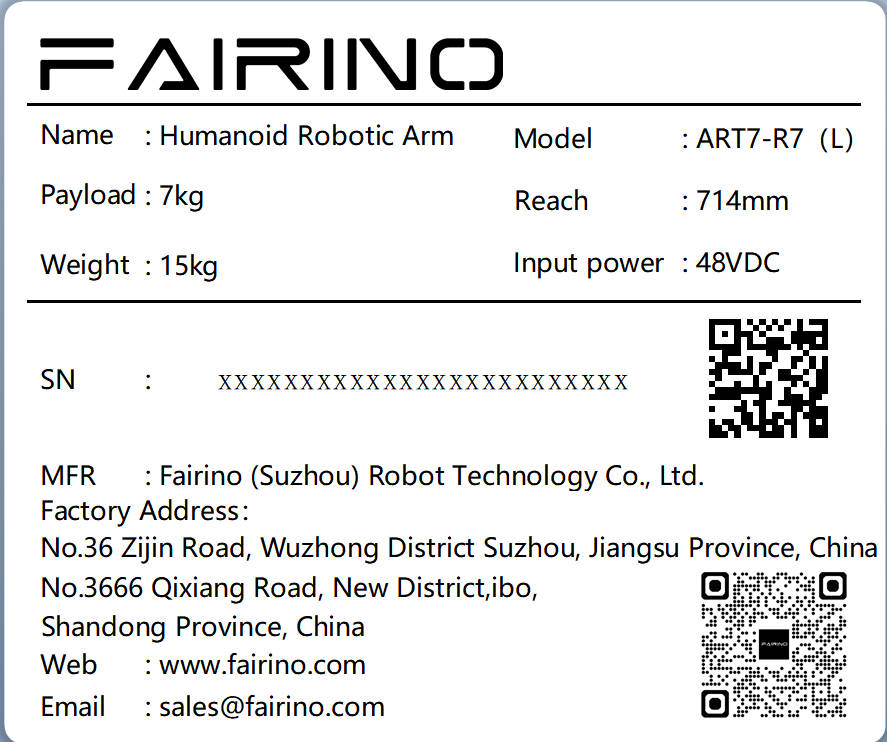
Figure 3-10 Configuration 4 Left Arm Nameplate Information
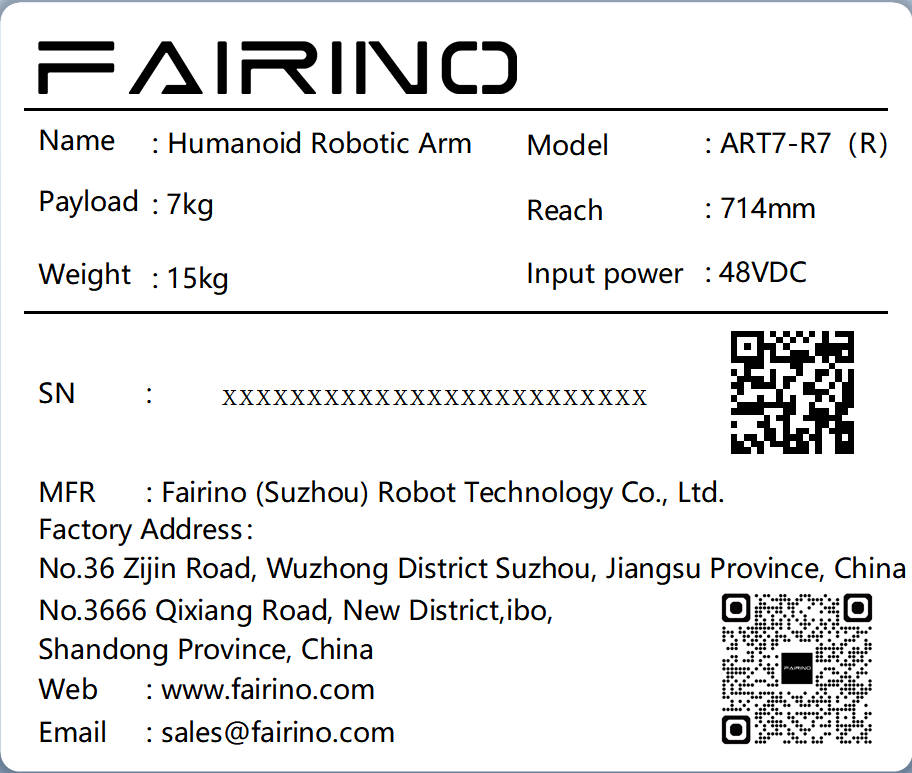
Figure 3-11 Right Arm Nameplate Information
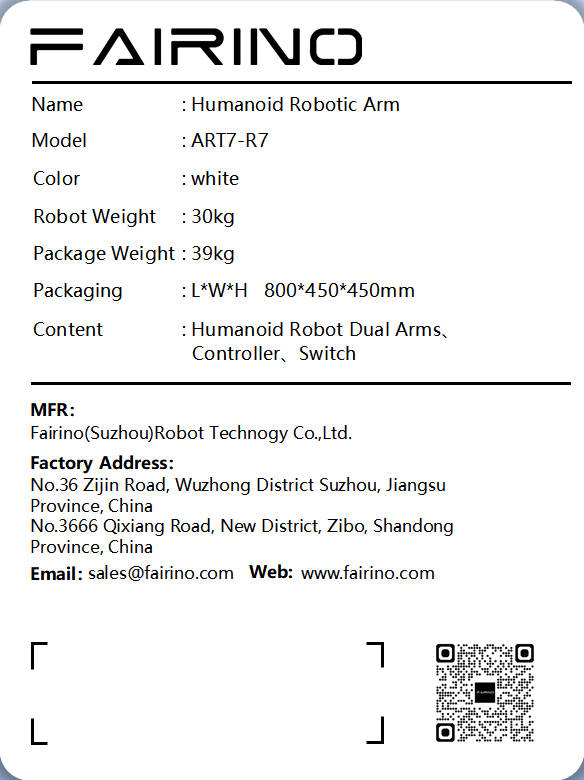
Figure 3-12 Configuration 4 Packing Box Nameplate Information
3.3. Technical Specifications
The technical parameters of the robotic arm are shown in Table 3-1.
Table 3-1 Technical Parameters
Parameter Type |
Specific parameters |
Model Parameters |
ART7-R7 |
Payload |
Single-arm 7kg |
Maximum working radius |
714mm |
Degrees of Freedom |
7 rotational degrees of freedom |
Scope of Work |
1Axis: ±175° |
Scope of Work |
2Axis:±112° |
Scope of Work |
3Axis:±175° |
Scope of Work |
4Axis:-87~+112° |
Scope of Work |
5Axis:±175° |
Scope of Work |
6Axis:±72° |
Scope of Work |
7Axis:±90° |
Joint Velocity |
≥150°/s |
Noise |
<65dB |
Installation Direction |
Any direction |
Repeat Positioning Accuracy |
±0.03mm |
Machine Weight |
About 15kg |
3.4. Joint Definition
The joint definitions of the left and right arms are shown in Figures 3-13 and 3-14.
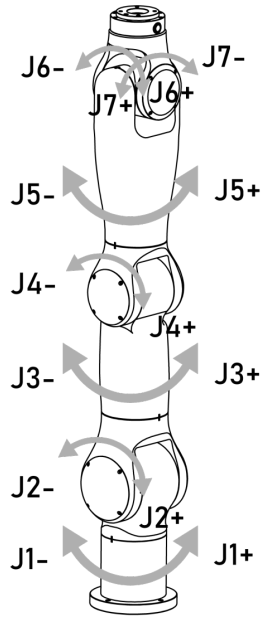
Figure 3-13 Left Arm Joint Definition
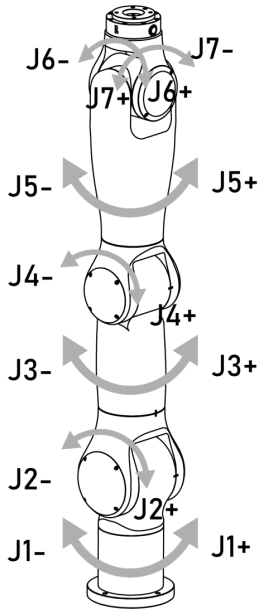
Figure 3-14 Right Arm Joint Definition
3.5. Range of Motion
The range of motion of the robotic arm is shown in Figure 3-15.
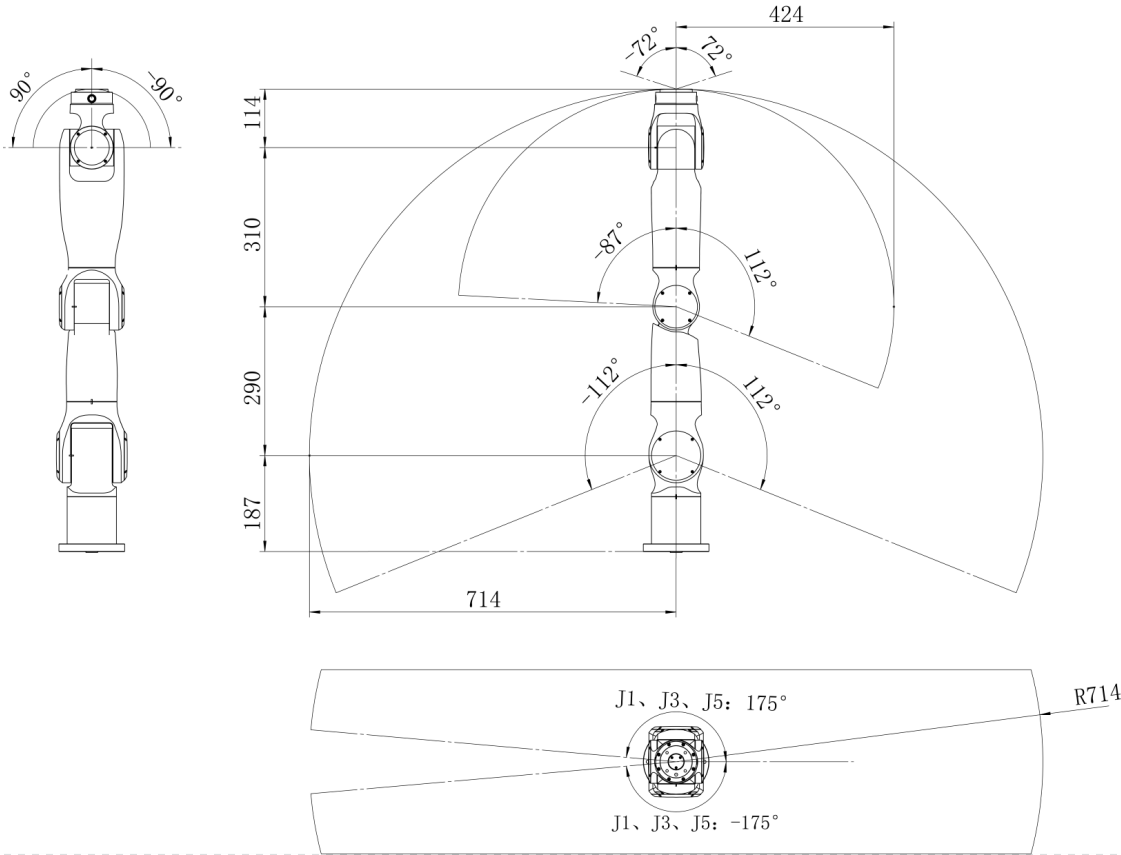
Figure 3-15 Robotic Arm Motion Range
3.6. DHParameters and Coordinate Systems
The left arm DH parameters are shown in Table 3-2 and Figure 3-16.
Table 3-2 Left Arm DH Parameter Table
joint_i |
θi |
di/mm |
ai |
αi/rad |
1 |
0 |
187 |
0 |
-pi/2 |
2 |
0 |
0 |
0 |
pi/2 |
3 |
0 |
290 |
0 |
-pi/2 |
4 |
0 |
0 |
0 |
pi/2 |
5 |
0 |
310 |
0 |
-pi/2 |
6 |
pi/2 |
0 |
0 |
pi/2 |
7 |
0 |
0 |
0 |
0 |
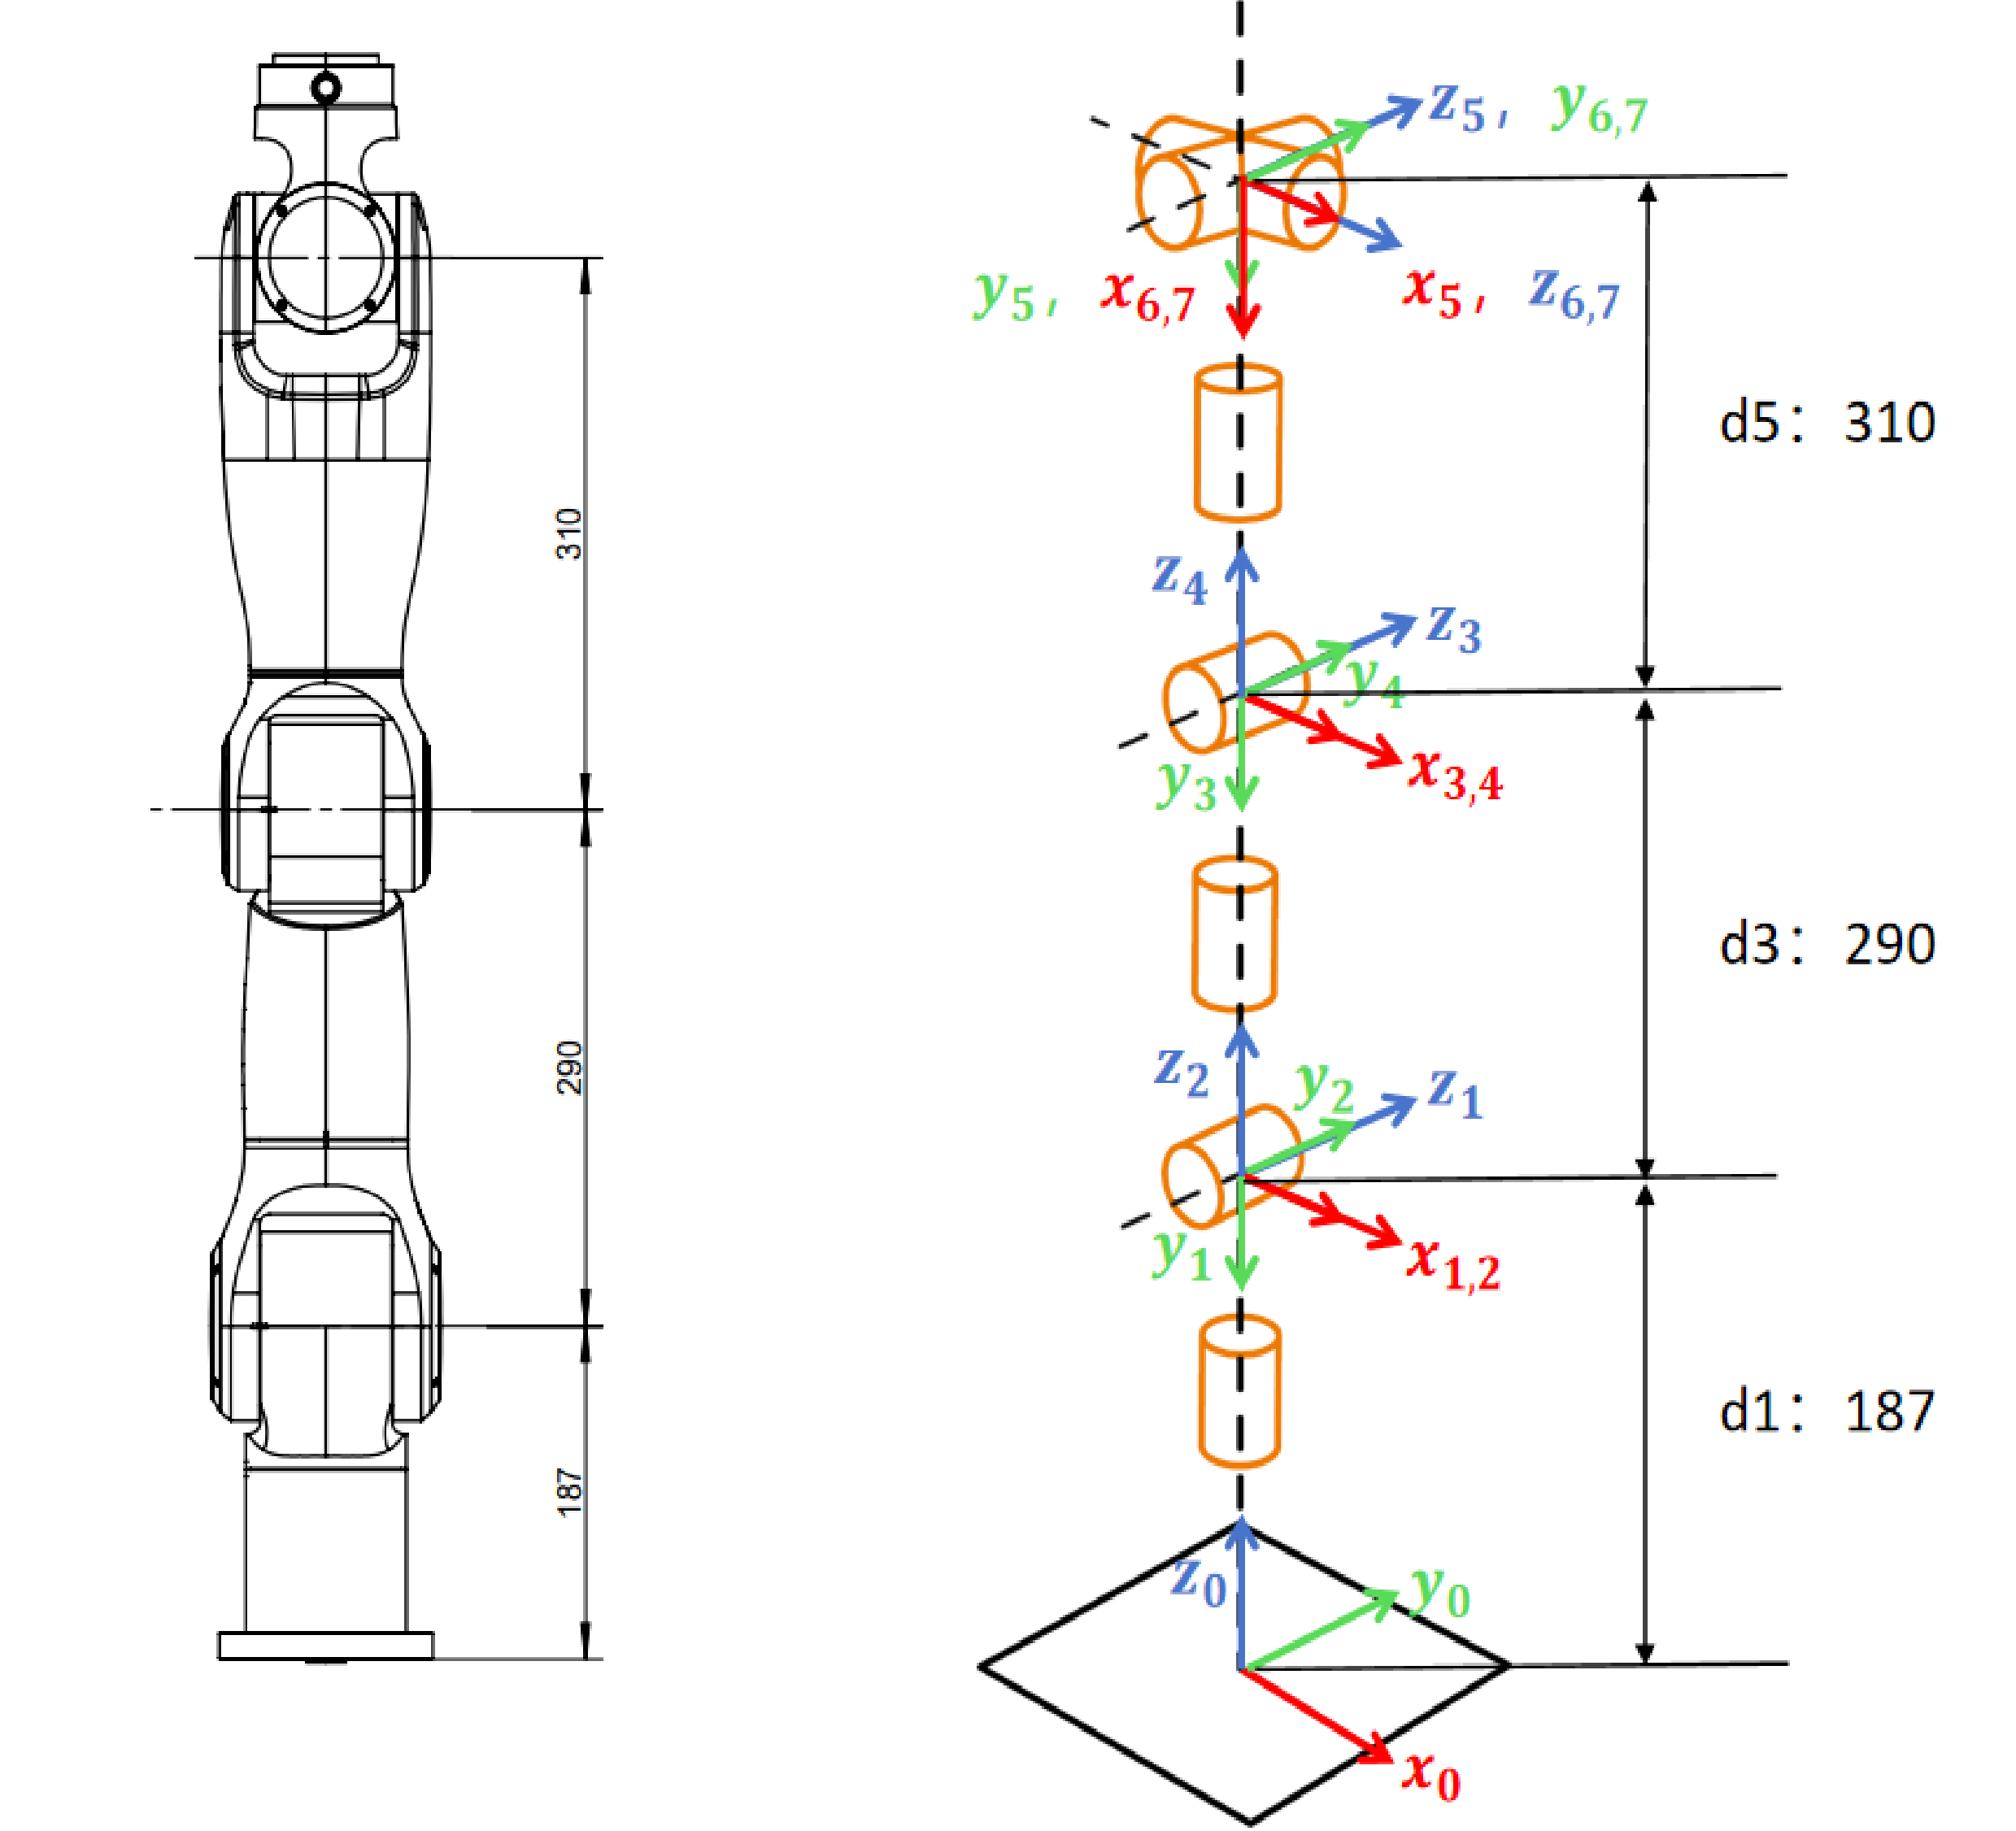
Figure 3-16 Left Arm Coordinate System
The right arm DH parameters are shown in Table 3-3 and Figure 3-17.
Table 3-3 Right Arm DH Parameter Table
joint_i |
θi |
di/mm |
ai |
αi/rad |
1 |
0 |
187 |
0 |
-pi/2 |
2 |
0 |
0 |
0 |
pi/2 |
3 |
0 |
290 |
0 |
-pi/2 |
4 |
0 |
0 |
0 |
pi/2 |
5 |
0 |
310 |
0 |
-pi/2 |
6 |
pi/2 |
0 |
0 |
pi/2 |
7 |
0 |
0 |
0 |
0 |
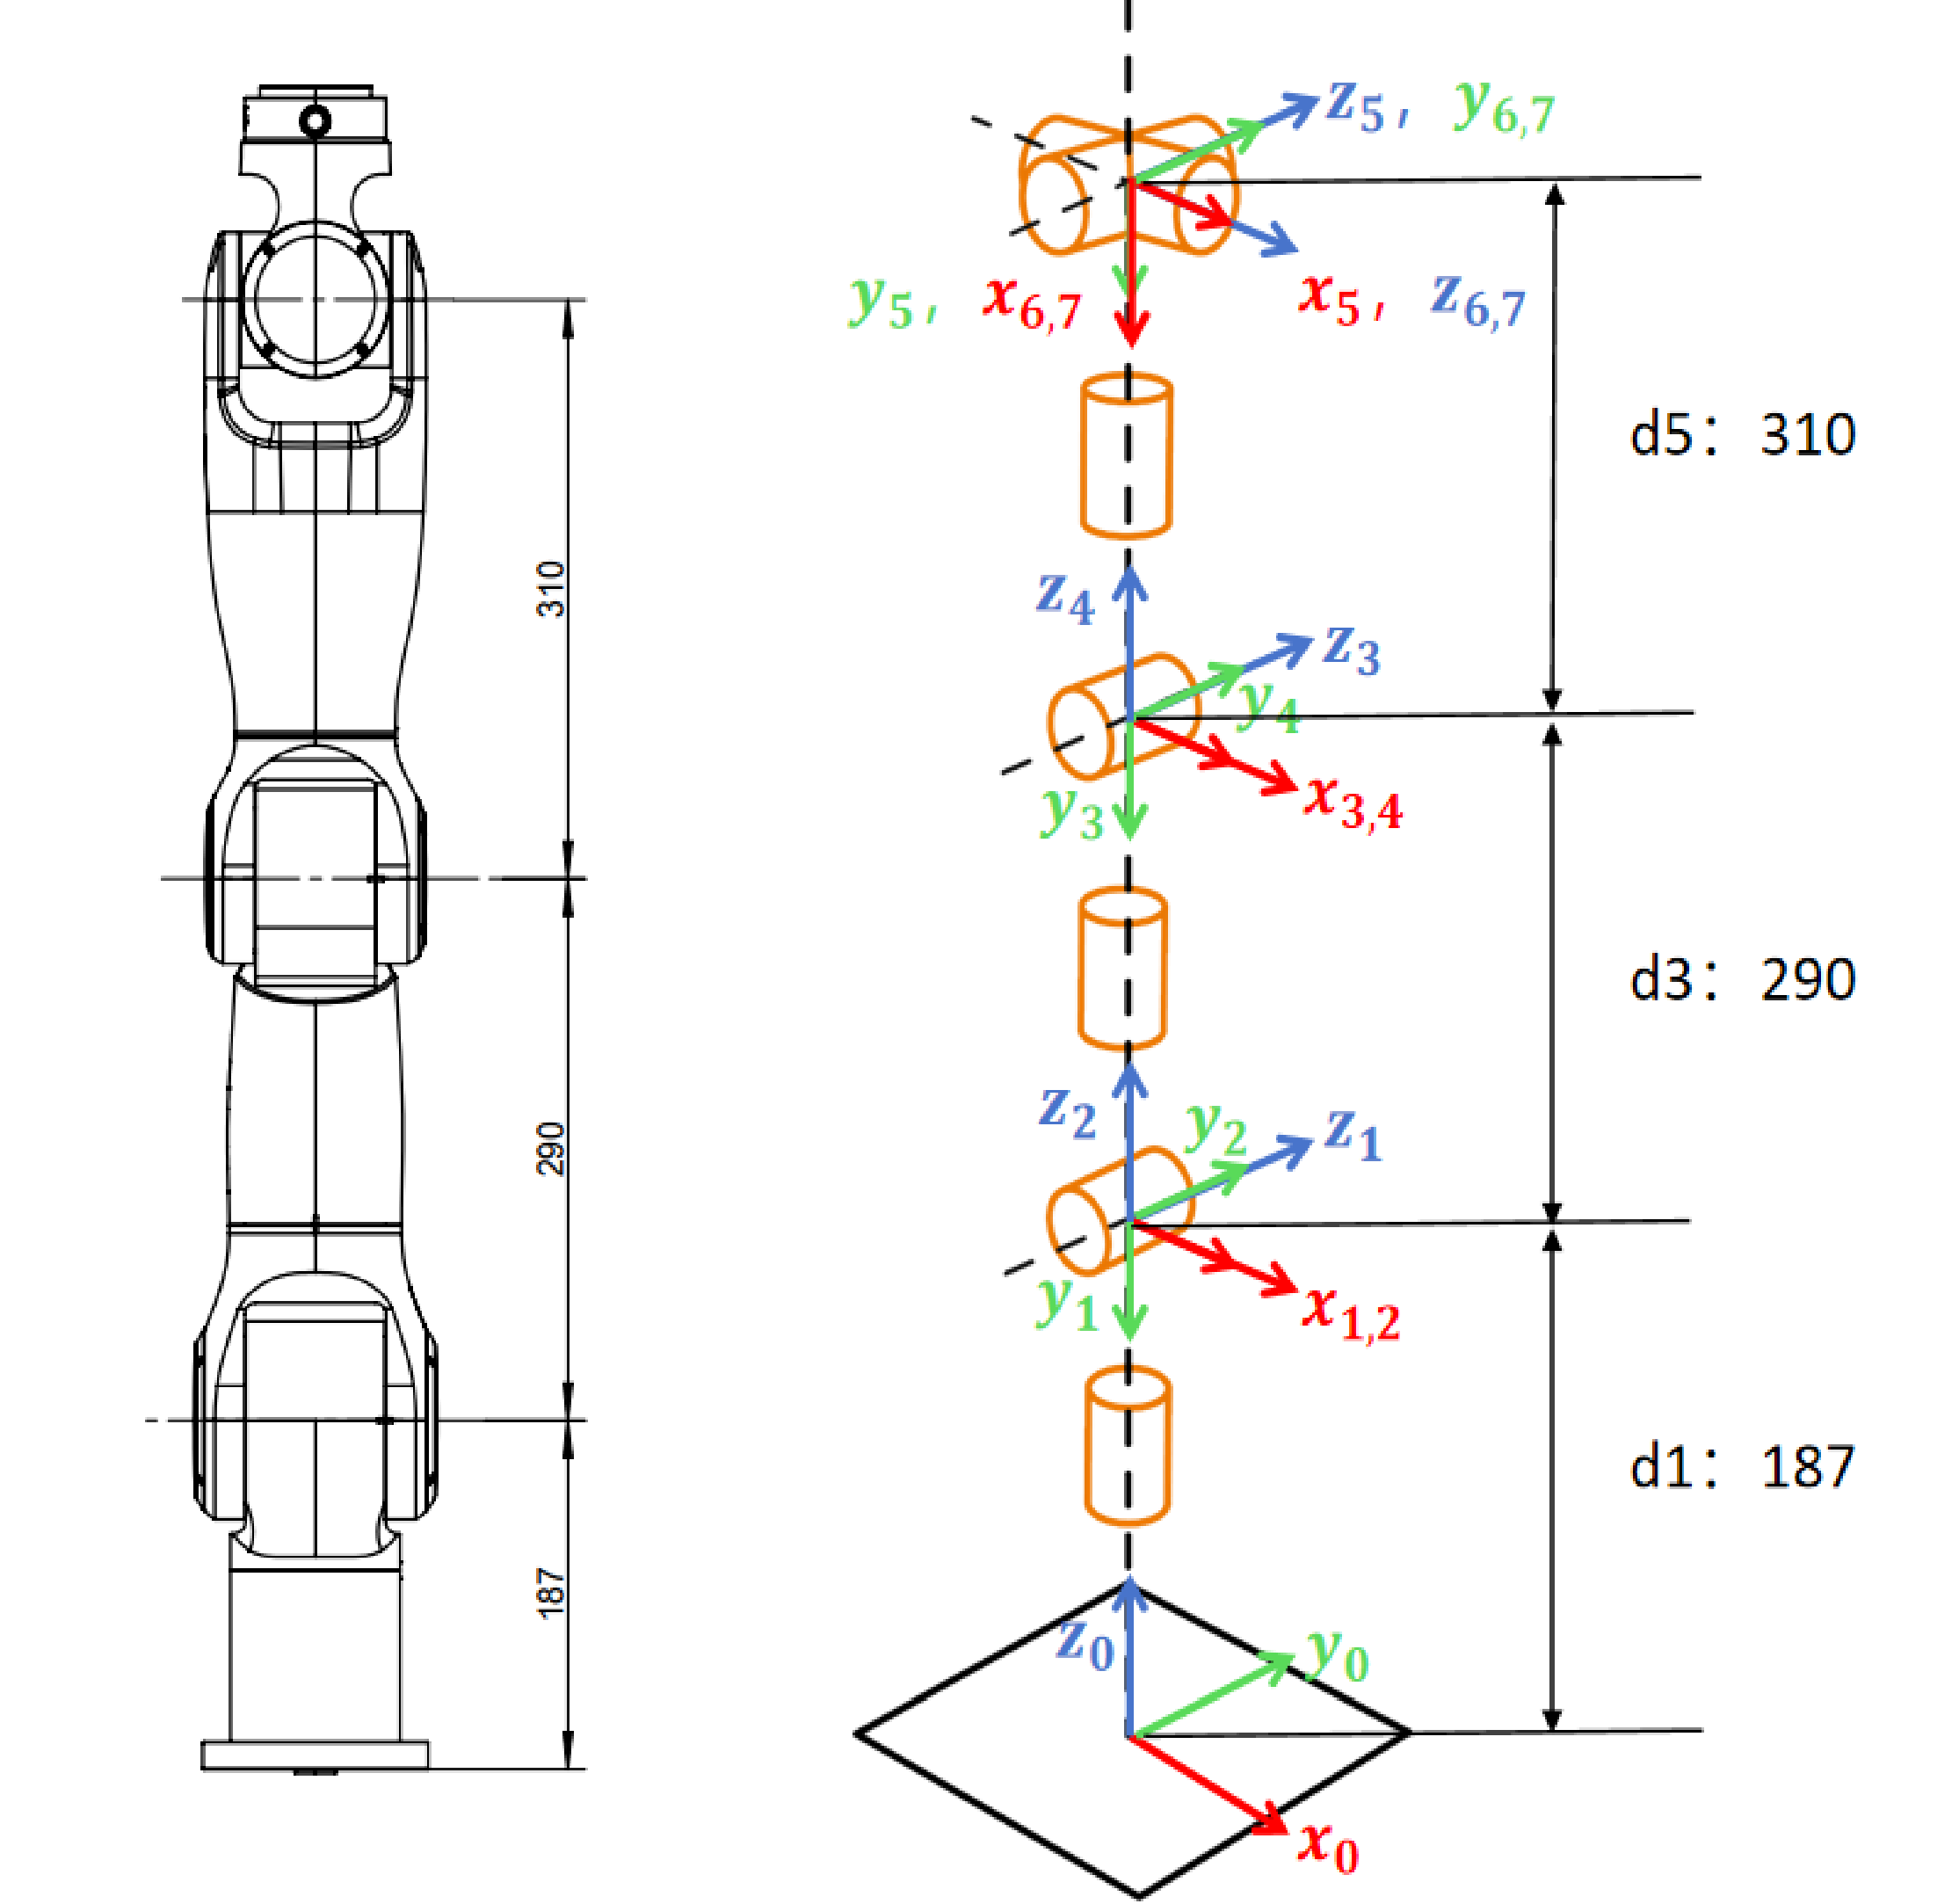
Figure 3-17 Right Arm Coordinate System
3.7. Tool Flange Dimensions
The dimensions of the end tool flange are shown in Figure 3-18.
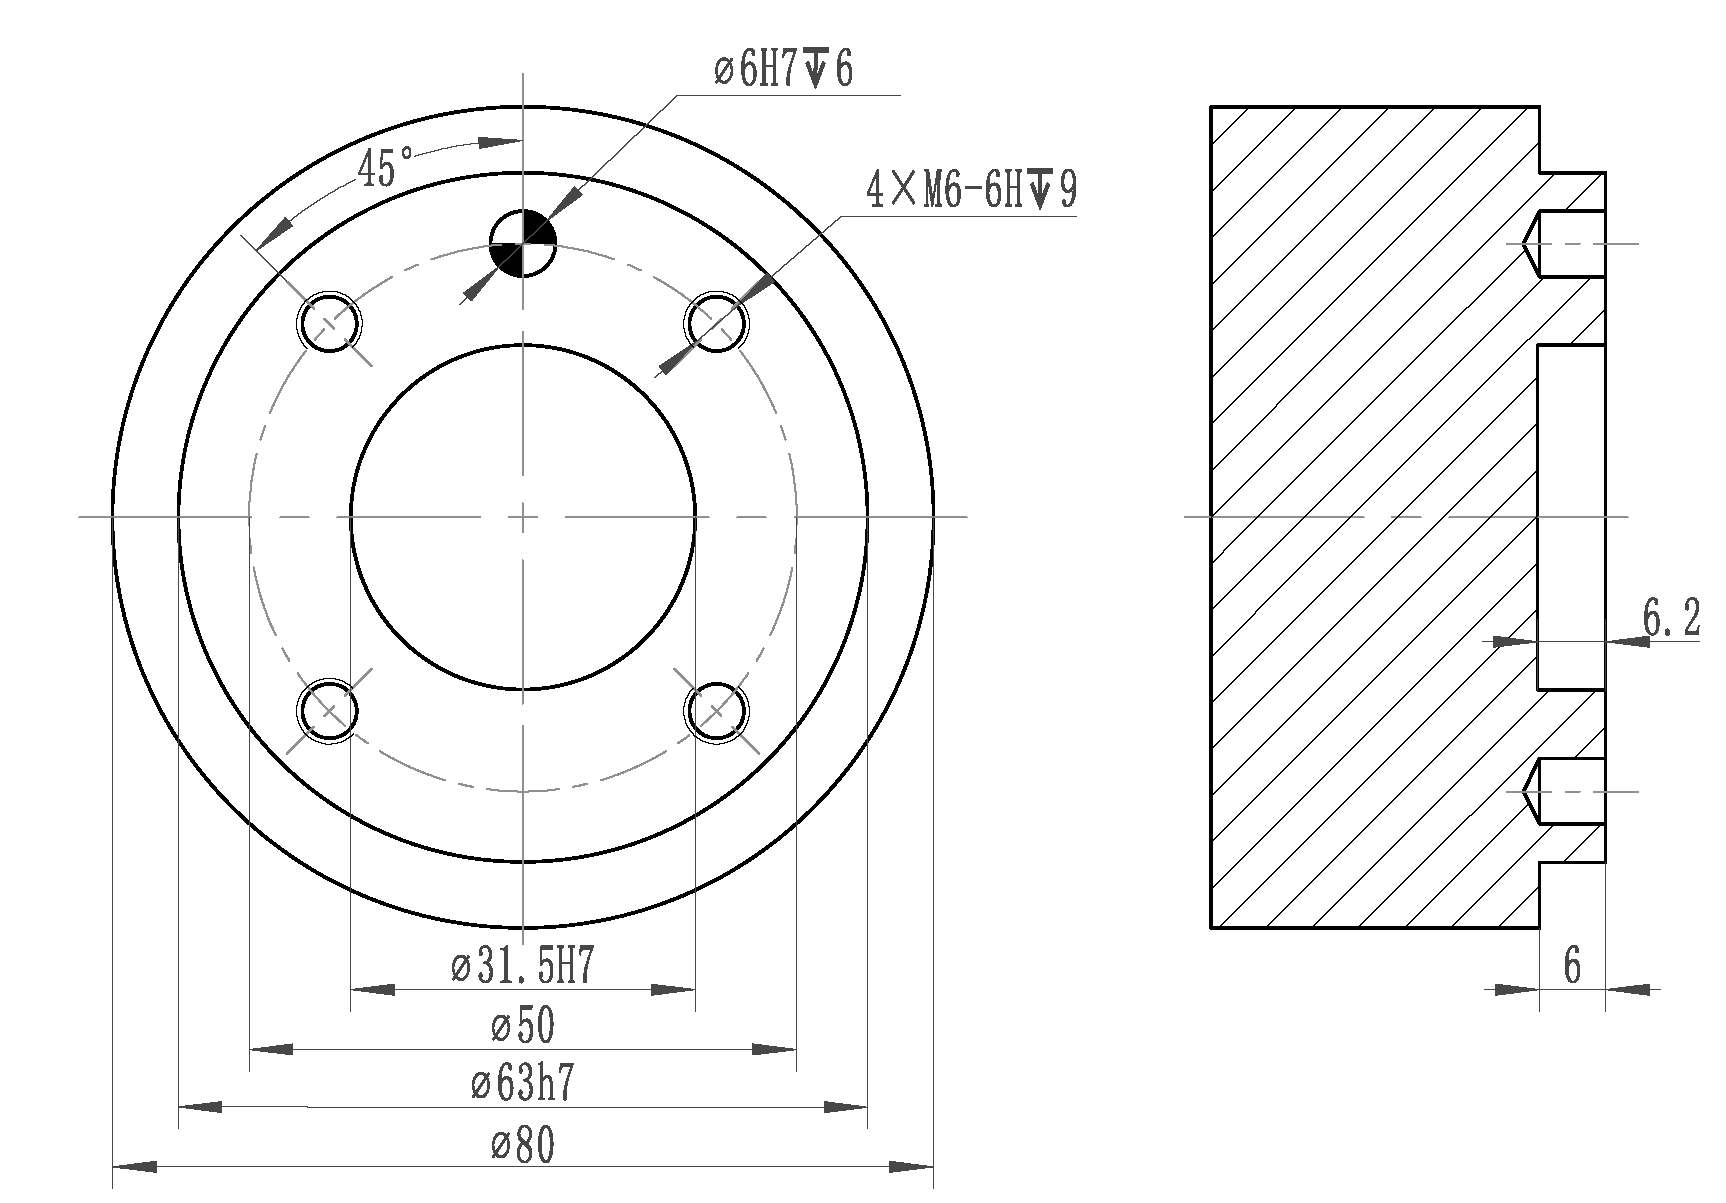
Figure 3-18 End Effector Flange Dimensions