1. Plugin Overview
The plugin is based on ROS 2 Control Humble for Ubuntu 22.04 LTS and is designed for low-level control of FA Robotics’ ART series products, featuring simple human-machine interaction capabilities. It is suitable for users integrating FA Robotics’ ART series products with MoveIt 2 or other ROS 2 ecosystem tools.
The plugin’s interaction logic is primarily divided into three components: the plugin status dashboard, the plugin command server, and the ROS2 controller that executes specific functions. The framework diagram is shown below:
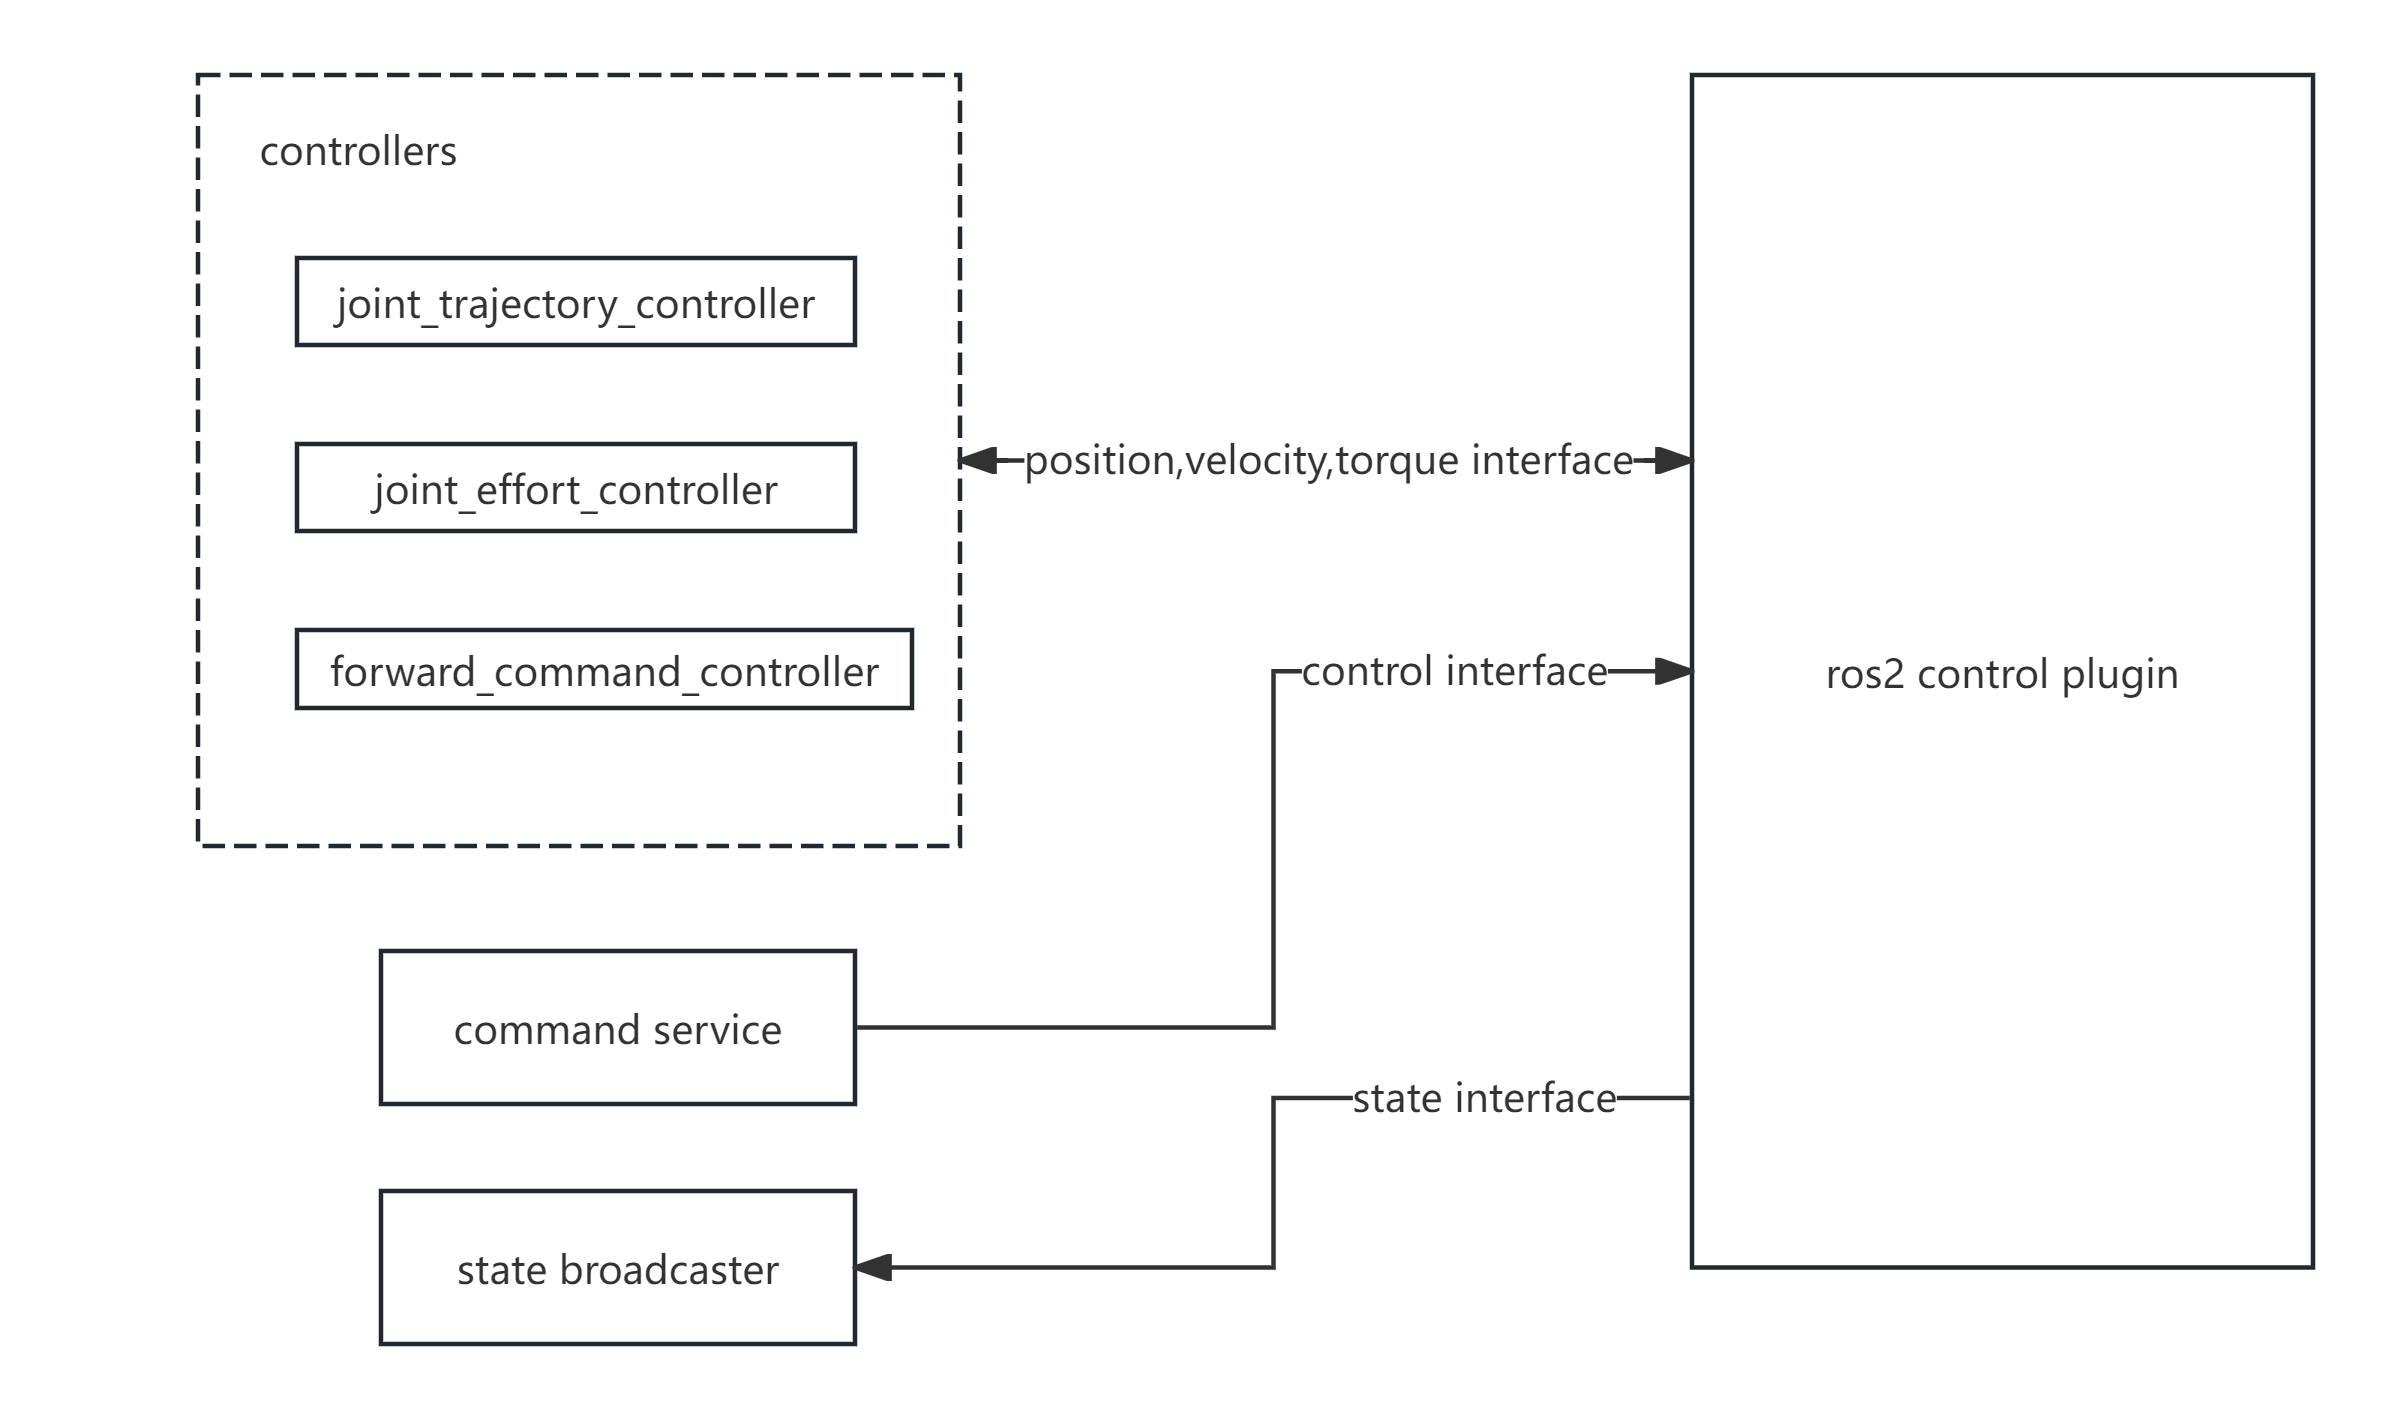
Figure 1-1 ARTPlugin Framework
The underlying ROS 2 Control plugin exposes numerous interfaces for EtherCAT devices: commanded joint position, velocity, torque, and control word, among others. For infrequently accessed interfaces—such as servo control words and I/O read/write operations—the plugin interfaces with a command server, which interacts with users via an Action server. For high-frequency read/write interfaces, direct access is provided to specific controllers, enabling them to interface with the user’s planner to achieve position, velocity, and torque control.
Note
Note: The ARTPlugin is launched automatically upon system startup, so no additional activation is required. As long as the dashboard service and command server described below are detected, the plugin is operating normally.